
POST-FLIGHT POSITIONING & SURVEY DATA PREPARATION
Prepare the positioning evidence before running a PPK calculation
A DJI Terra PPK workflow uses compatible recorded positioning observations to calculate positions after capture. It can be useful when a live RTK correction link is unreliable, provided the drone and reference data were recorded correctly.
This guide covers file preparation, time coverage, base coordinates, a documented Matrice 4E and D-RTK 3 example, and result validation. It distinguishes local visible-light PPK from LiDAR procedures, which have their own inputs and release requirements.
RTK and PPK: different timing, the same need for usable observations
RTK applies corrections during acquisition. PPK uses recorded observations in a post-processing calculation. Losing a live correction connection does not necessarily mean the survey must be repeated, but a later calculation needs a suitable record of the capture and reference station.
DJI’s Matrice 4E local PPK announcement describes a drone-and-base workflow for calculating position information after the flight.
PPK does not repair every type of missing evidence
It cannot recreate observations that were not recorded, restore a missing camera event time by assumption, sharpen blurred images or recover geometry hidden from the sensor. Assess the cause of an RTK gap before choosing the remedy.
Our accuracy, GCP and RTK guide provides the wider control strategy. This article focuses on preparing and checking the PPK calculation itself.
Confirm the exact sensor and software workflow
A platform’s ability to record GNSS data does not automatically establish support for every native PPK calculation in Terra. Check the aircraft or payload, firmware, task type, file format, Terra release and applicable entitlement together.
| Workflow | What to check | Reference to use |
|---|---|---|
| Visible-light local PPK | Eligible image capture, event records, GNSS files and base data. | Current visible-light instructions for the aircraft and Terra release. |
| LiDAR position or trajectory processing | Complete payload folders, GNSS/IMU data and the supported base-file route. | Sensor-specific LiDAR processing documentation. |
| External positioning calculation | Compatible third-party processing and the declared output reference. | Processor documentation and Terra POS import requirements. |
The example below follows DJI’s published Matrice 4E + D-RTK 3 method. For LiDAR, consult the separate DJI LiDAR PPK instructions. Legacy naming rules should not be transferred to a newer workflow without checking its manual.
Use our supported drones and sensors guide and release notes guide to prepare the compatibility questions.
Keep the complete drone recording, not only the photographs
Preserve the original task folders and their relationships. DJI’s photogrammetry accuracy white paper describes photo-event timing and GNSS observation files used in supported capture workflows.
| Record | Role | Preparation check |
|---|---|---|
| MRK event record | Photo timing and associated positioning information. | Keep it with the correct images and capture task. |
| OBS observation data | Recorded GNSS observations in a RINEX workflow. | Confirm the applicable format, version and time coverage. |
| RTK observation record | DJI binary observations used in an eligible Terra calculation. | Retain the original record rather than renaming unrelated files. |
| Navigation and other task files | Supporting information used by the applicable processing route. | Preserve the complete folder and follow the sensor-specific instructions. |
These examples are not a universal file checklist for every aircraft. Compare the actual folder with the documentation for the selected system. Save an untouched archive before organizing a working copy.
Do not rename images, edit timestamps or change extensions as a general “fix”. A filename change does not convert the contents of an unsupported observation file.
Match base observations to the capture time
The reference recording must cover the relevant drone observations. Check the start and end of both recordings, data gaps and the time convention used by the files.
- Record mission dates and any flight or battery boundaries.
- Distinguish UTC, local clock time and GNSS time conventions.
- Check whether base observations are split across multiple files.
- Retain enough documented coverage for the selected processing method.
- Confirm that each capture task is associated with the correct reference data.
For example, a site team may describe a flight as starting at 10:00 local time while a base filename uses UTC. Matching those labels without conversion can select a different recording period. Use the actual file metadata and documented time convention.
If the flight crosses midnight or spans segmented reference files, check the complete period before processing. Follow the applicable import method instead of manually concatenating binary files by guesswork.
Review the base coordinate and antenna reference
A consistently processed trajectory can still be shifted if the reference station coordinate is wrong or expressed in a different datum. Keep the base position, height reference and source of that position with the project.
- Identify whether the coordinate comes from an accepted known point or another documented determination.
- Record horizontal datum and the meaning of the height value.
- Confirm the antenna reference and how antenna height is handled by the selected workflow.
- Check entered units, axis order and coordinate fields.
- Keep the original survey record and any approved transformation separately.
Do not apply a height correction twice
Trace whether the supplied base coordinate refers to the survey mark or the antenna reference, and how the processor uses antenna height. Follow the equipment and software definitions rather than adding a generic offset.
Use our coordinate system and geoid guide when the target output uses a different reference. A correct-looking horizontal overlay does not establish a correct engineering height.
A documented Matrice 4E and D-RTK 3 local PPK example
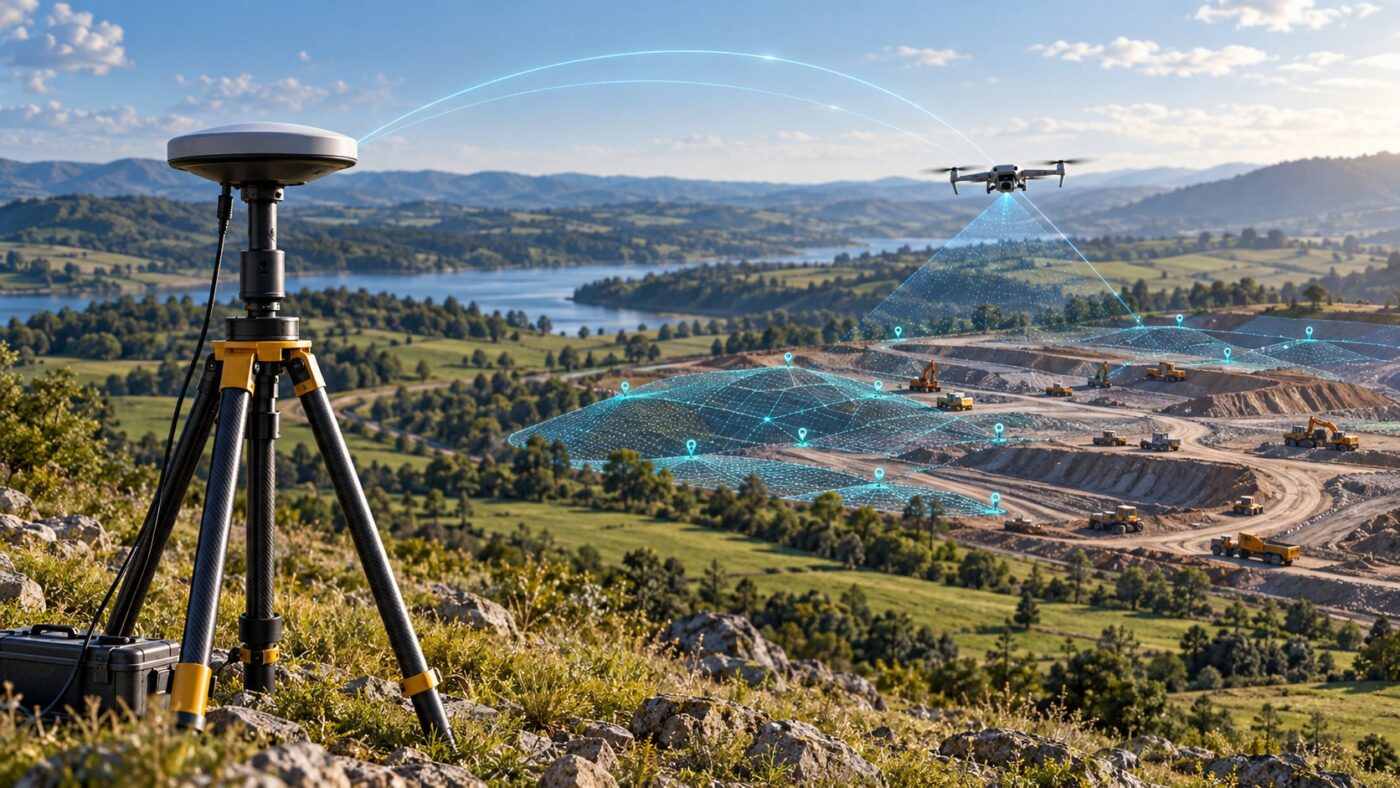
DJI describes placing D-RTK 3 at a known point in base-station mode, collecting a Matrice 4E mapping task while the station records, and importing both datasets into Terra for local PPK. The software recognizes the eligible drone and base observations in that documented route.
- Confirm compatible firmware, Terra release and the intended visible-light processing task.
- Prepare the base position and recording according to the D-RTK 3 instructions.
- Complete the capture and preserve both original recordings.
- Create the applicable Terra project and review the imported data.
- Select the supported local PPK route and add the corresponding base data.
- Review the reference settings, run the calculation and inspect its outcome.
- Continue reconstruction only after the positioning result is suitable for the project.
The workflow is described in the official DJI announcement and tutorial. Use the current manual for exact interface steps and file requirements.
Do not infer that another camera or base file is supported solely because this example works. Confirm the alternative configuration before field capture.
Validate the result independently of the solution status
Review the processor’s output and any unresolved observation or timing issues. Then evaluate the reconstructed deliverable against independent known positions and elevations in the target reference.
A successful calculation or a fixed-solution label is evidence about the processing, not a complete acceptance test. Check the distribution of validation points and whether they represent the difficult parts of the survey.
- Compare the same independent observations before and after an assessed processing change.
- Inspect horizontal and vertical residuals separately.
- Investigate consistent shifts and residual patterns across the site.
- Review reconstructed geometry, coverage and image or strip alignment.
- Record control points used in adjustment separately from independent checks.
Our quality report guide explains how to interpret processing indicators. Keep the PPK records alongside the accepted reconstruction revision.
Common PPK preparation problems
| Symptom | Possible input issue | Next check |
|---|---|---|
| Base data is rejected | Unsupported contents or format version. | Compare the recording with the sensor-specific support list. |
| Too little matching coverage | Wrong period, data gaps or missing segments. | Review actual observation times and all required files. |
| Output is consistently shifted | Base coordinate or datum interpretation. | Compare independent known positions in the target reference. |
| Elevations disagree | Antenna reference, height system or units. | Trace height handling through the complete workflow. |
| Some captures lack useful positioning | Missing events or usable observations. | Review the original task records and decide whether supplementary control or recapture is needed. |
Preserve unsuccessful calculation records and note the settings changed between attempts. Repeatedly trying different base coordinates until the map appears to align is not a defensible processing method.
For a general project failure, see our reconstruction troubleshooting guide.
Keep a positioning note with the delivered survey
- Aircraft or payload and capture dates.
- Original drone and reference-station data locations.
- Base-coordinate source, datum, height definition and antenna information.
- Processing software release, route and selected parameters.
- Calculation outcome and any excluded or unresolved periods.
- Output reference and any transformation used.
- Control strategy and independent validation results.
Keep the native processing records even if the recipient mainly uses the final GeoTIFF, cloud or model. For repeat surveys, a documented reference method helps explain whether an apparent change is physical or related to processing.
DJI Terra PPK workflow FAQ
Can PPK help when network RTK drops out?
It can help in an eligible workflow when usable drone and reference observations were recorded. Investigate the capture records and cause of the gap before assuming that every missing live correction can be recovered.
Can I run PPK with photographs alone?
The method requires the applicable positioning and timing observations as well as the image data. Preserve the complete supported recording, not only exported photographs.
Do all PPK base formats work with every Terra task?
No. Supported contents, versions and import procedures depend on the sensor and software route. Check the current instructions for the actual configuration.
Does PPK remove the need for independent checks?
No. Validate the delivered survey against the project requirements using appropriate independent evidence.
Does PPK mean I never need an internet connection?
Post-flight positioning avoids dependence on a live correction link during capture. Internet access may still be relevant to base-data retrieval, licensing or other software operations. Review the activation and deployment guide separately.
Check PPK compatibility before the next capture
Tell us your aircraft or payload, base station, Terra release and required outputs. We can help identify the relevant Terra processing and licensing requirements; use the responsible survey team’s reference definitions for the project.
Official documentation
- DJI Matrice 4E and D-RTK 3 local PPK workflow
- DJI capture records and photogrammetry accuracy white paper
- DJI separate LiDAR PPK processing instructions
- DJI D-RTK 3 manuals and downloads
- DJI Terra documentation and software releases
Independent guide by Drone Emotions. Documentation reviewed on 12 October 2026. Consult the documentation for the installed software and capture-system releases.


